Vehicle-to-Vehicle Communication using Free Space Optics
Overview
Radio frequency (RF) bands utilized for vehicular communications face increasing spectrum congestion and susceptibility to electromagnetic interference. Free-Space Optics (FSO) offers an alternative, highly directional line-of-sight communication medium with high data integrity.
In this project, developed for ECE4005 - Optical Communication Networks at Vellore Institute of Technology, I designed and prototyped an end-to-end Free-Space Optical Vehicle-to-Vehicle (V2V) telemetry system from scratch, complete with custom transceivers, a physical-layer framing protocol, and error-recovery mechanisms.
System Architecture
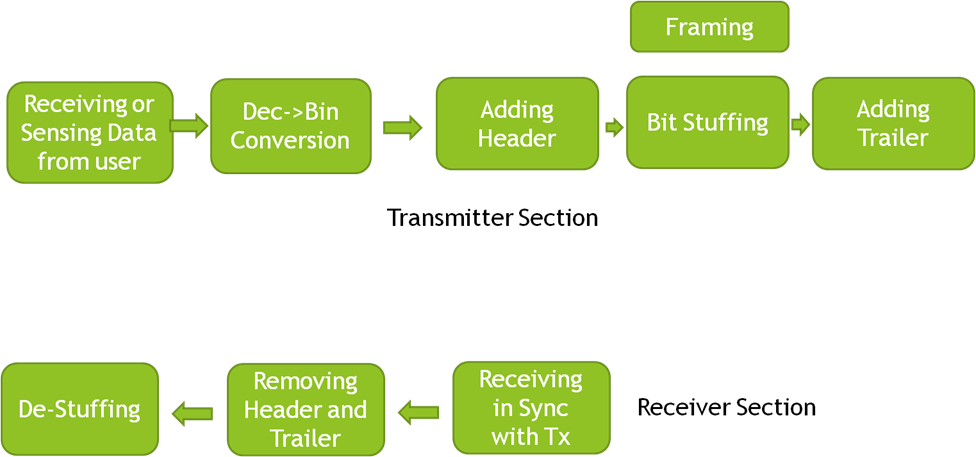 Figure 1: Transmitter and receiver hardware architecture for optical vehicle telemetry.
Hardware Implementation
1. Transmitter Circuit
Input telemetry (braking status, lane-change indicators, speed) is collected from vehicle control interfaces, framed by an embedded microcontroller, and modulated onto a collimated laser diode transmitter.
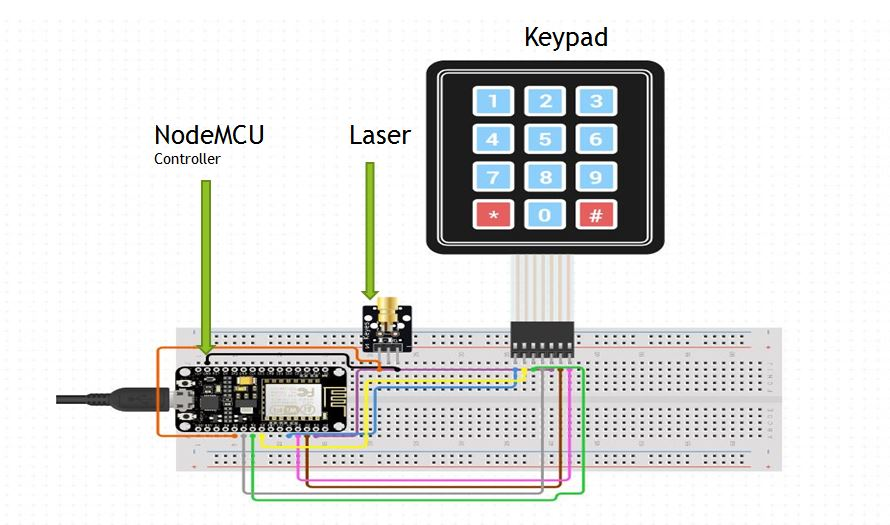 Figure 2: Laser transmitter circuit schematic and driver stage.
2. Receiver Circuit
A high-sensitivity photodetector array receives the modulated optical signal, applies thresholding to resolve binary pulses, and passes the bitstream to the receiver microcontroller for frame synchronization and telemetry decoding.
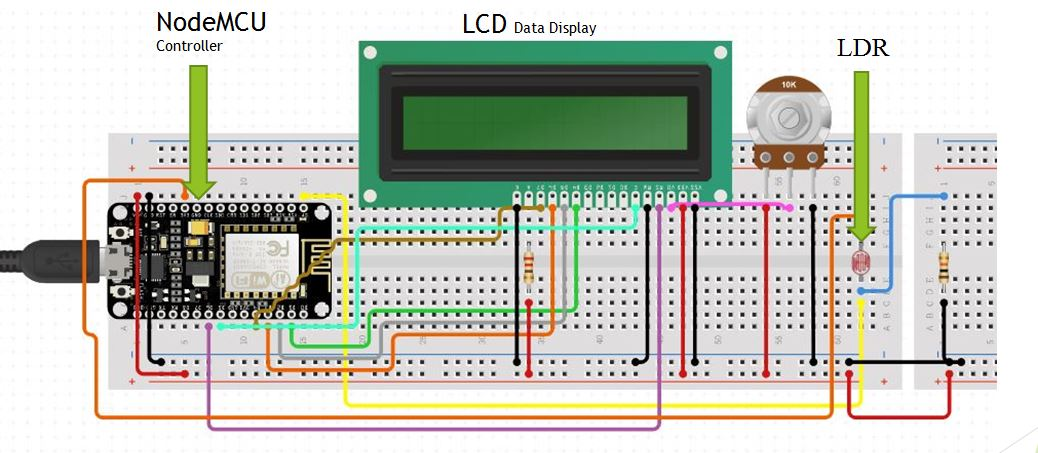 Figure 3: Optical receiver circuit schematic with signal conditioning.
Protocol Design & Synchronization
Frame Structure
A custom 17-bit frame was designed to balance throughput with error recovery over optical channels:
- Header: 4 bits (
1011) - Data Payload: 9 bits:
- Lane change indicator: 1 bit (Left / Right)
- Braking alert: 1 bit (Active / Inactive)
- Vehicle speed: 7 bits (0 – 127 km/h range)
- Trailer: 4 bits (
1010)
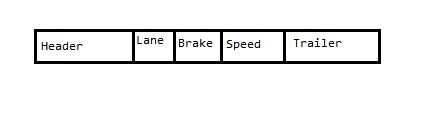 Figure 4: 17-bit optical telemetry packet structure.
Error Recovery & Bit Stuffing
- Bit Stuffing: Implemented bit-stuffing rules to ensure that reserved header and trailer flag sequences do not appear within the data payload, preventing false synchronization.
- Stop-and-Wait ARQ: Sender transmits a frame and waits for an optical acknowledgment (ACK). If no ACK is received within a 1.5-second timeout window, the frame is retransmitted. The receiver dynamically resynchronizes to the next incoming frame using header flag detection if intermediate bits are dropped.
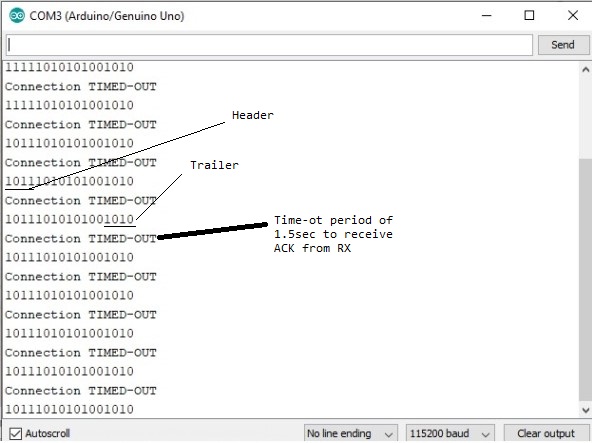 Figure 5: Oscilloscope traces showing transmitted and received optical pulse streams under synchronization.