EasyGo: Edge Vision-Based Real-Time Parking Space Detection
Overview
Urban parking congestion significantly increases transit time, fuel consumption, and urban emissions. Traditional smart parking solutions require expensive in-ground inductive loops or ultrasonic sensors embedded in every parking stall, leading to prohibitive installation and maintenance costs.
EasyGo is an edge computer vision solution that eliminates dedicated in-ground hardware by using a single monocular camera paired with an edge microprocessor to continuously detect, track, and report individual parking slot occupancies in real time.
- Source Code: GitHub Repository (rishi1134/EasyGo)
System Pipeline & Technical Details
- Edge Neural Detection: Deployed quantized MobileNet-SSD and lightweight YOLOv2 object detection models on a Raspberry Pi 3B+ edge unit.
- Polygon Region-of-Interest (ROI) Mapping: An administrative calibration module allows one-time polygonal demarcation of parking stalls. Real-time vehicle bounding boxes are mapped to pre-calibrated stall coordinates using intersection-over-union (IoU) spatial thresholds.
- Telemetry & Synchronization: Detection state updates are pushed to a centralized cloud database, enabling real-time slot reservation and availability routing via web and mobile interfaces.
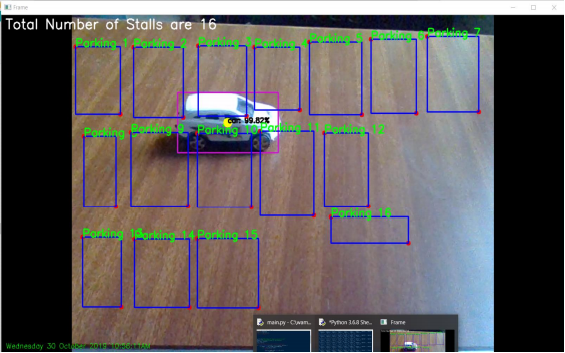 Figure 1: Real-time vehicle detection and parking stall occupancy tracking running on the edge processing pipeline.